
From Grasshopper Model to Robot Code
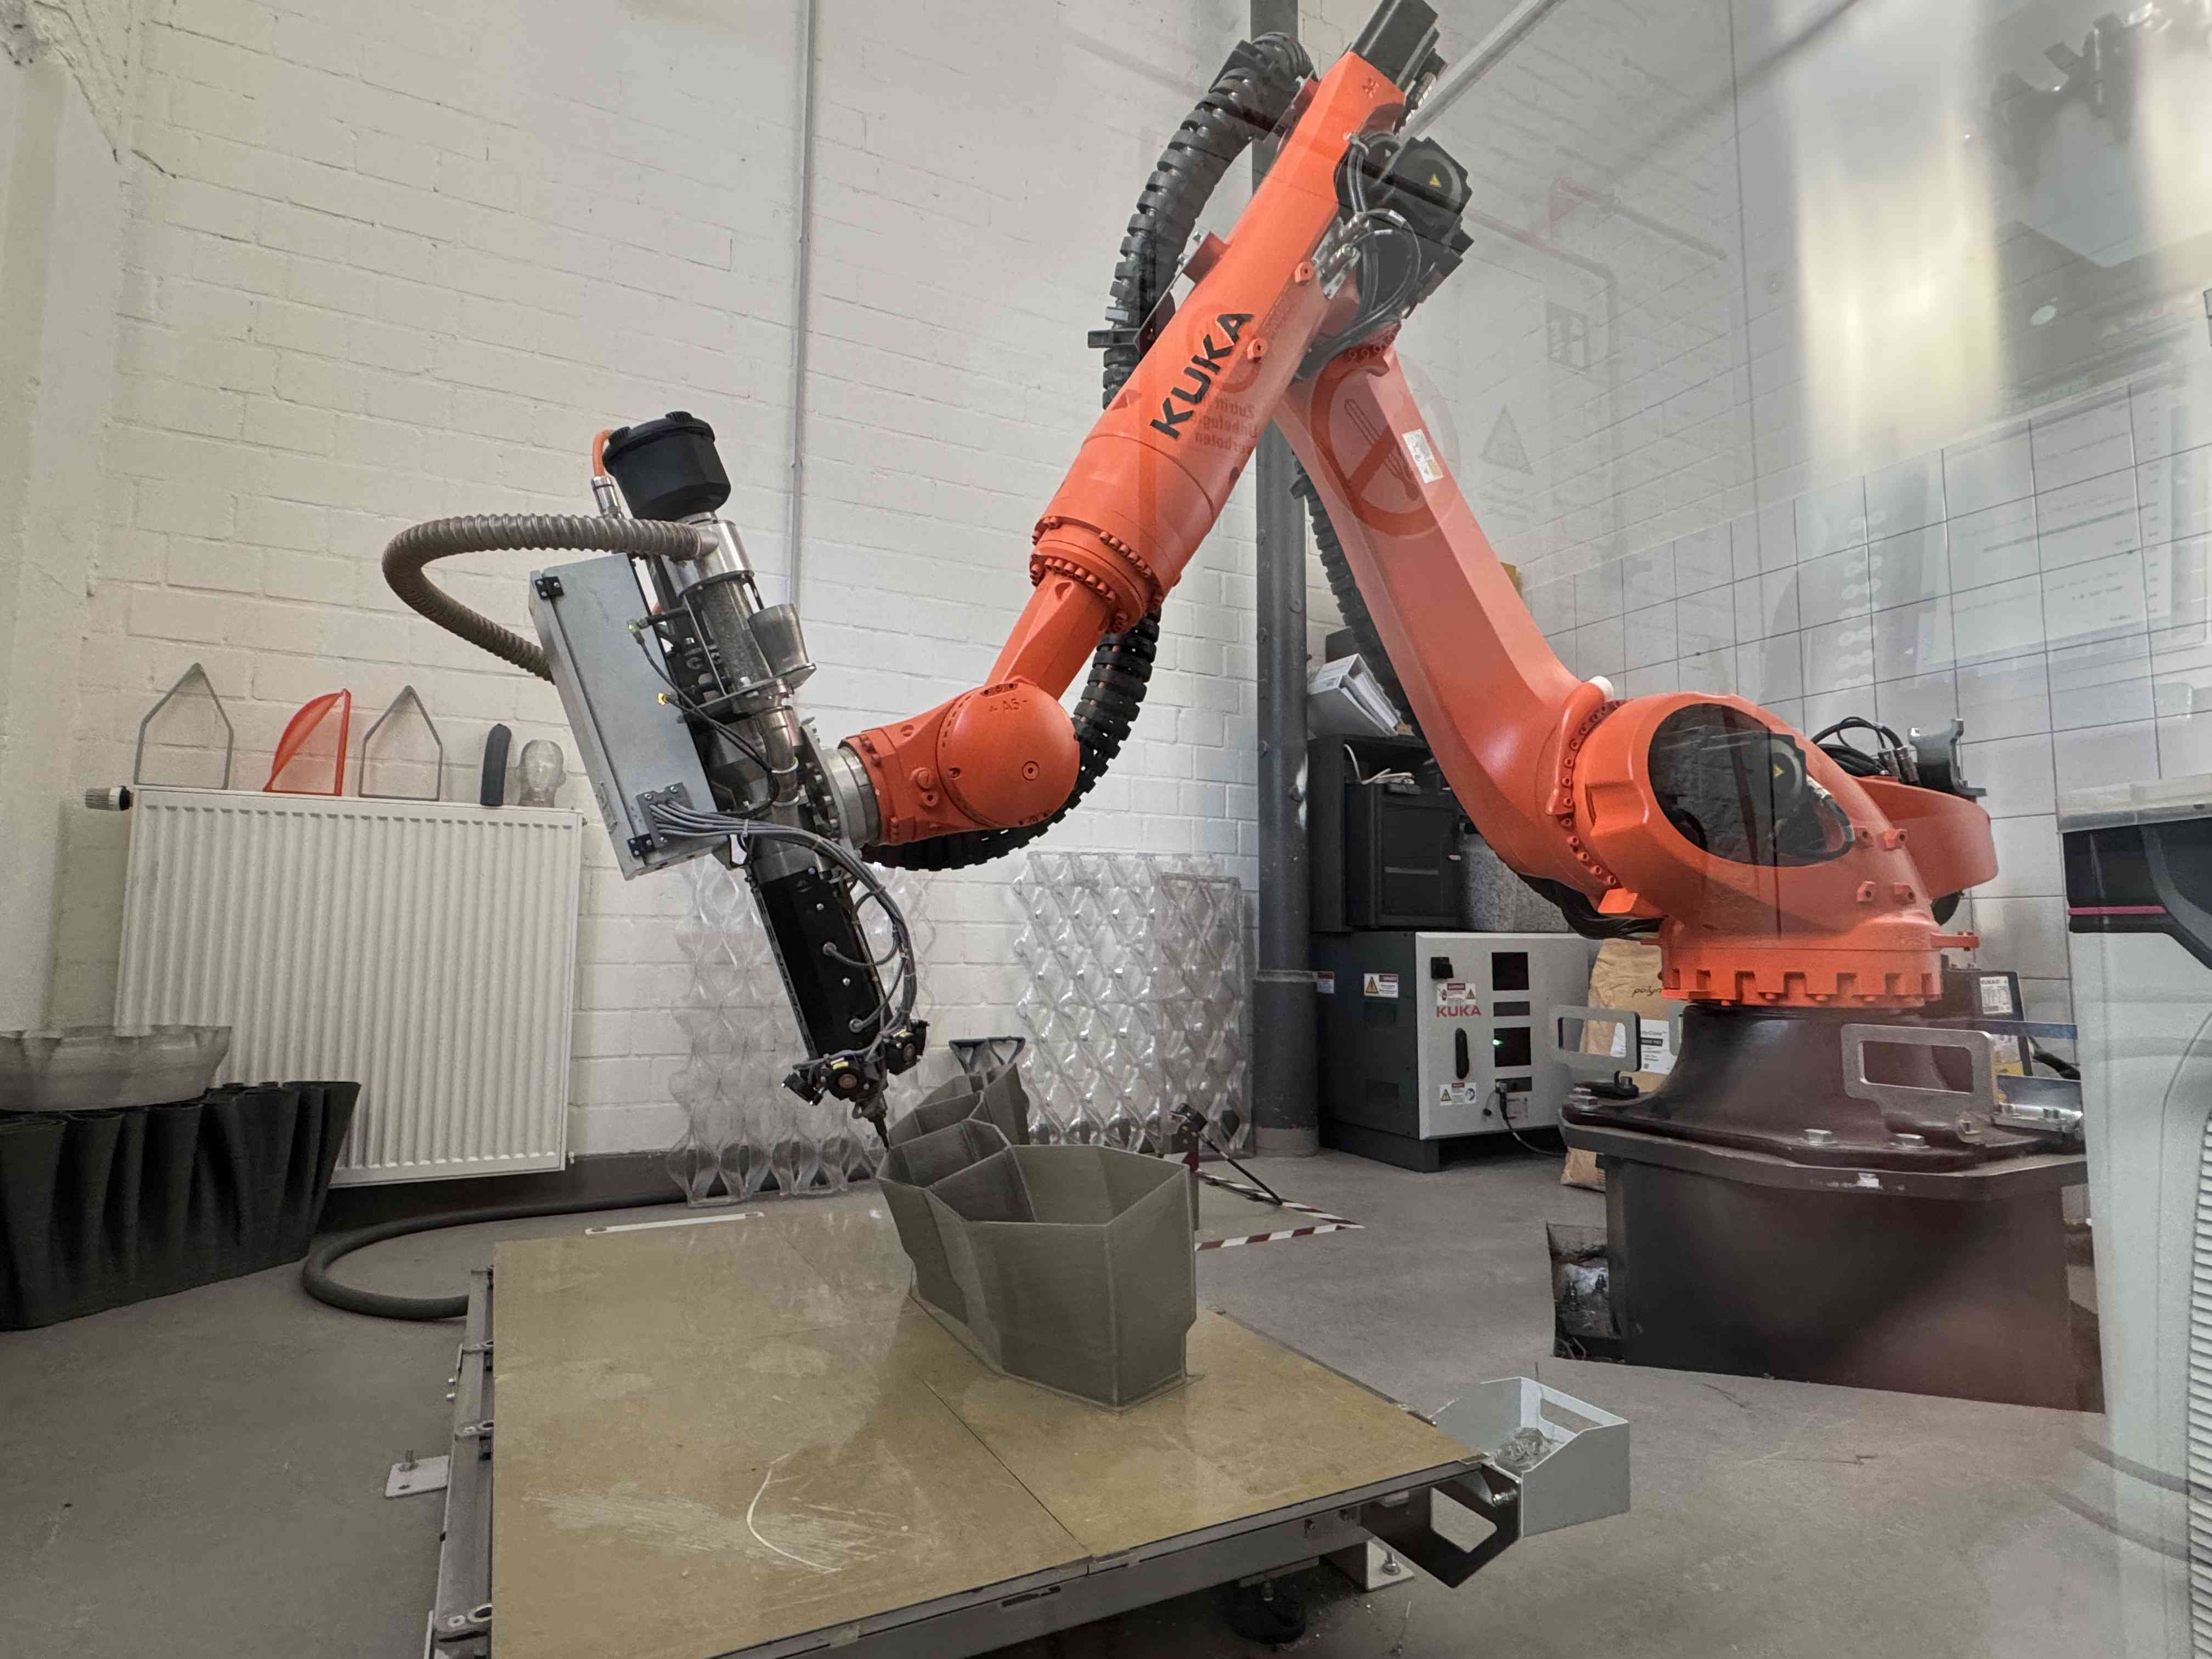
LARGER.slicer is a Grasshopper toolkit for Rhino that we developed at the robotics.lab of FH Münster (MSA Münster School of Architecture). It turns surfaces, curves and points into toolpaths and machine-ready code for large-format 3D printing: G-code for the Ginger One pellet printer and DXR robot code for the Weber DXR25 with a KUKA KR120 robot.
Students, researchers and partners of the lab use it to get from a parametric design to a physical print – without a separate slicer and without writing robot code by hand.
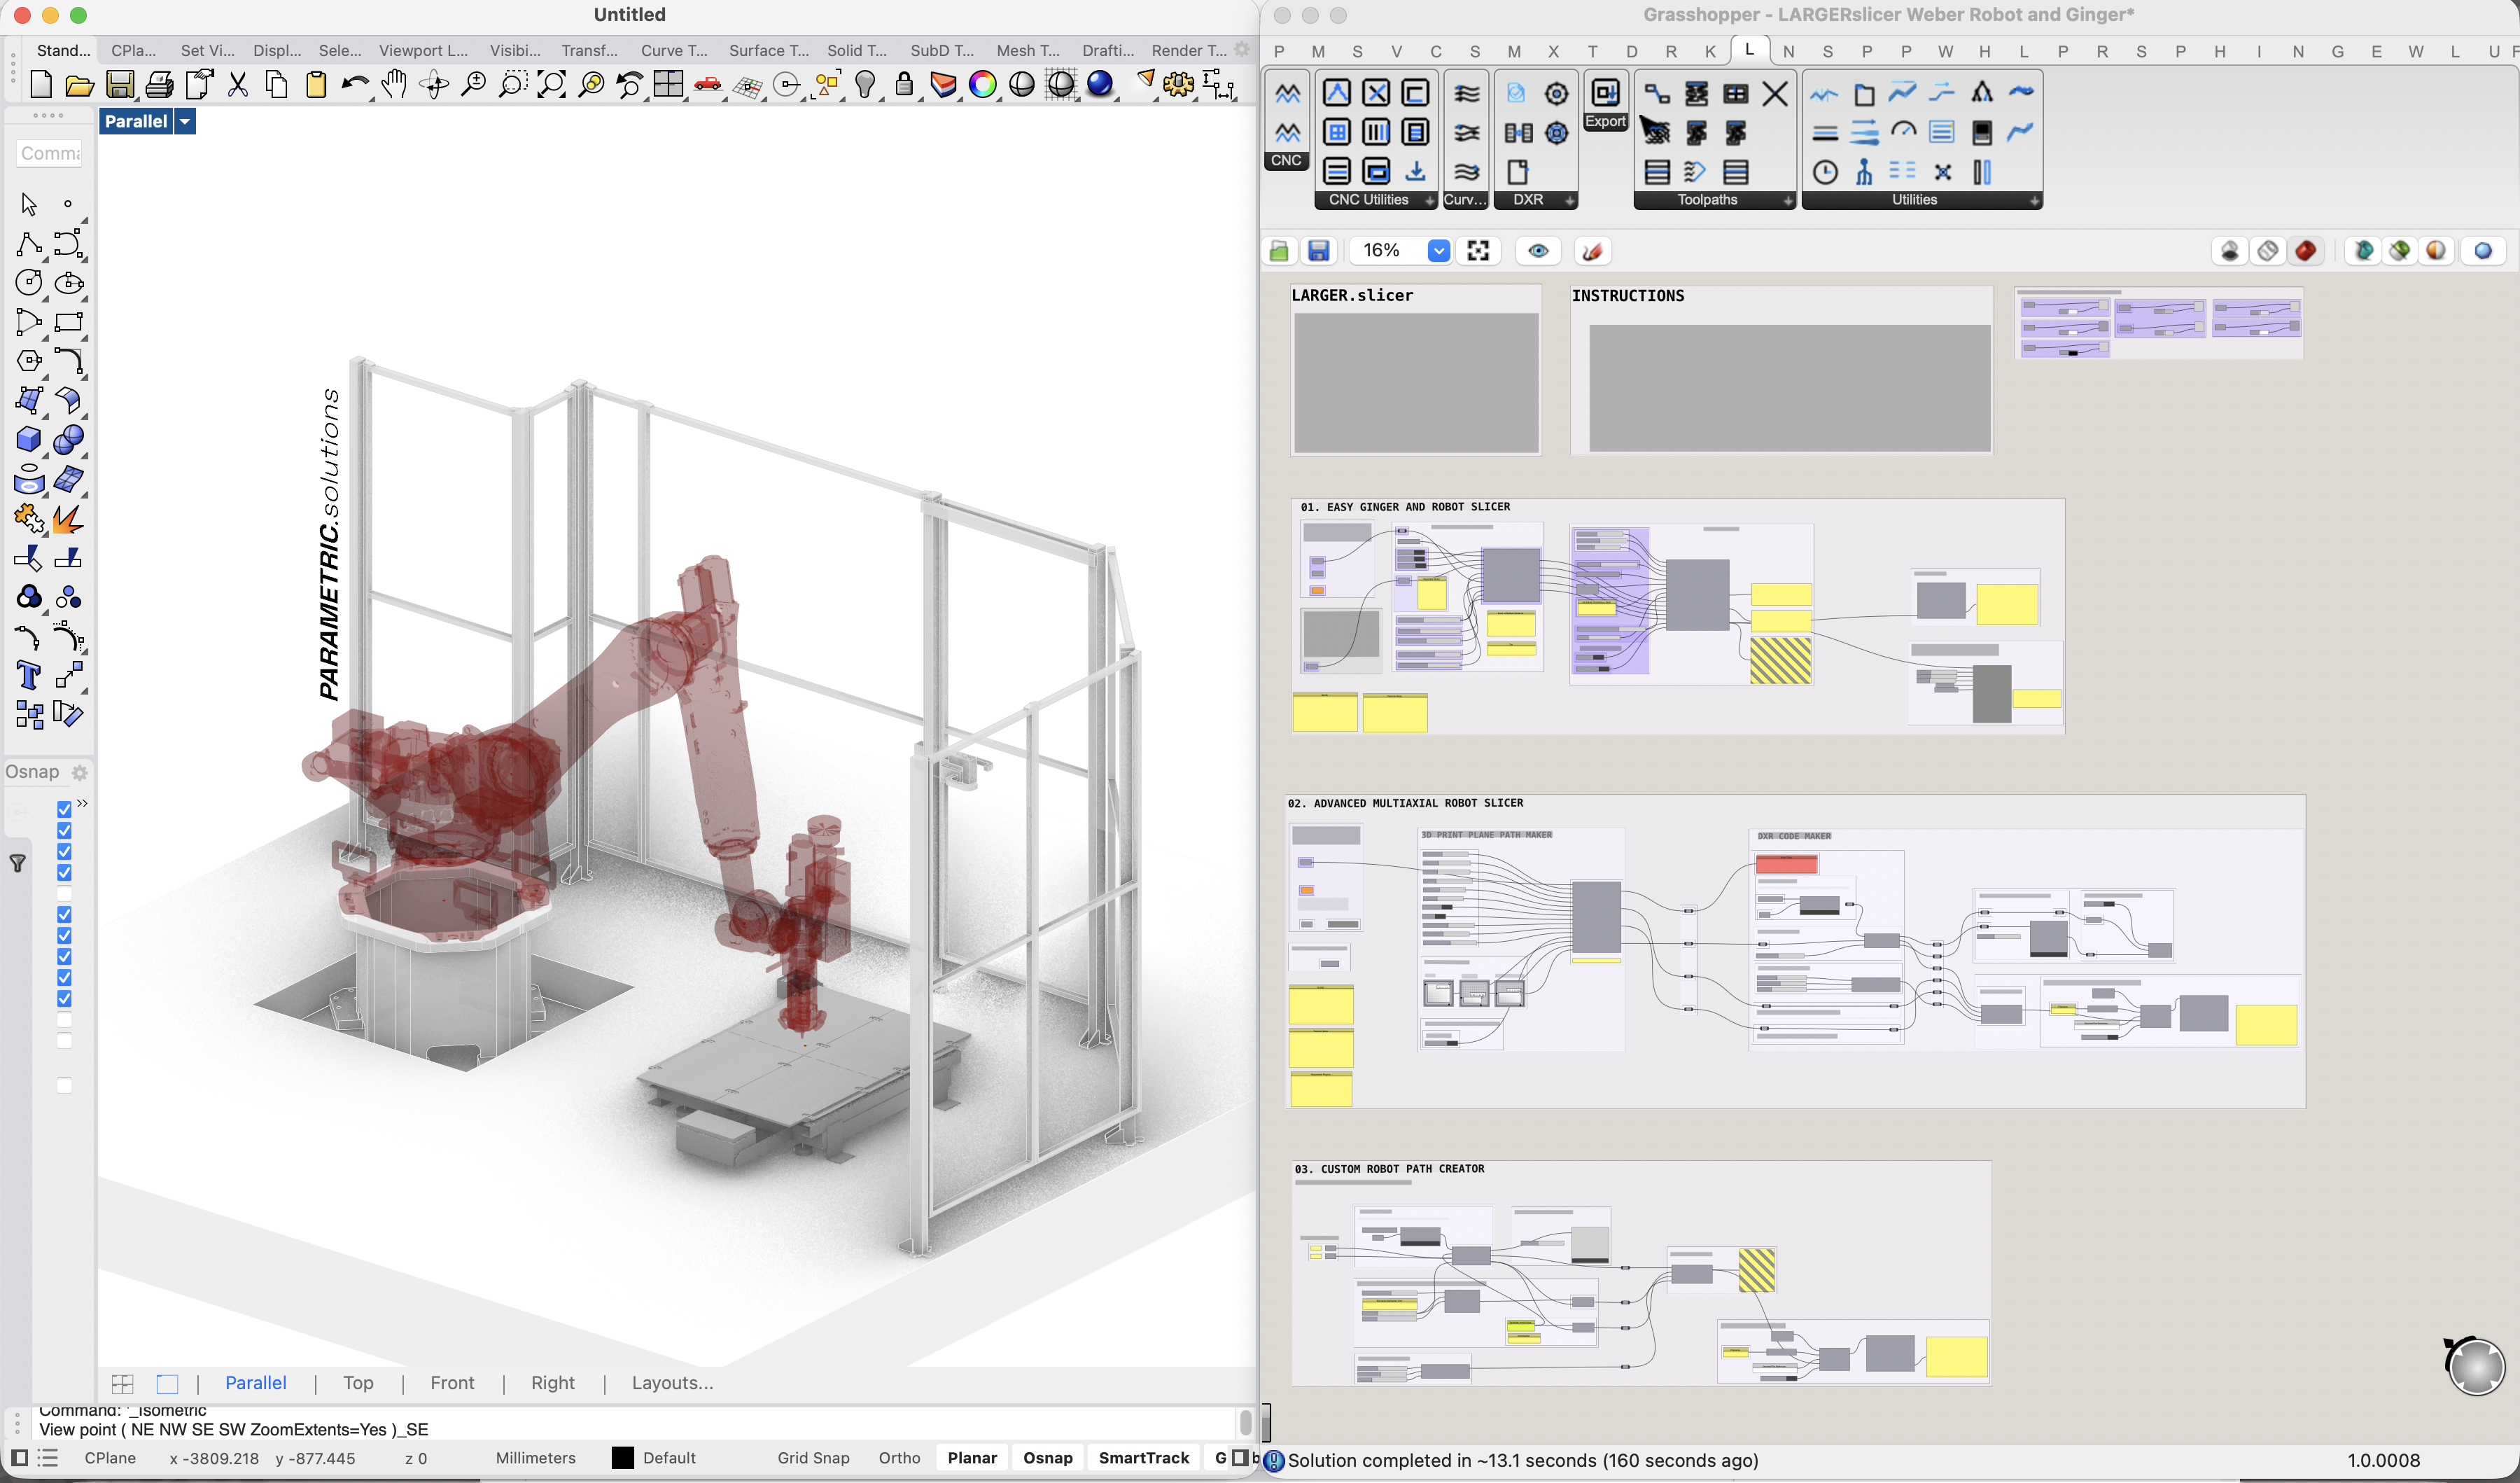
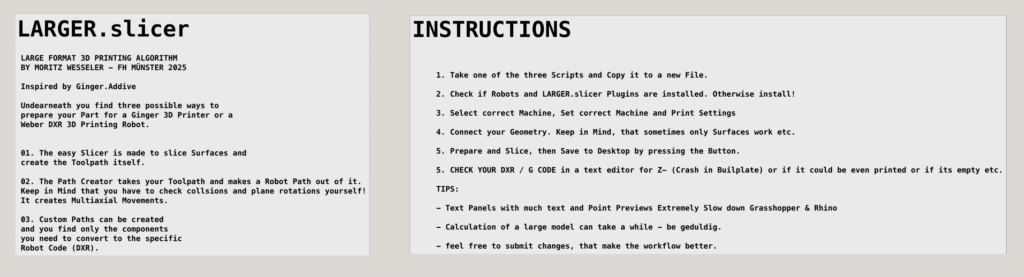
Three Workflows in One Definition
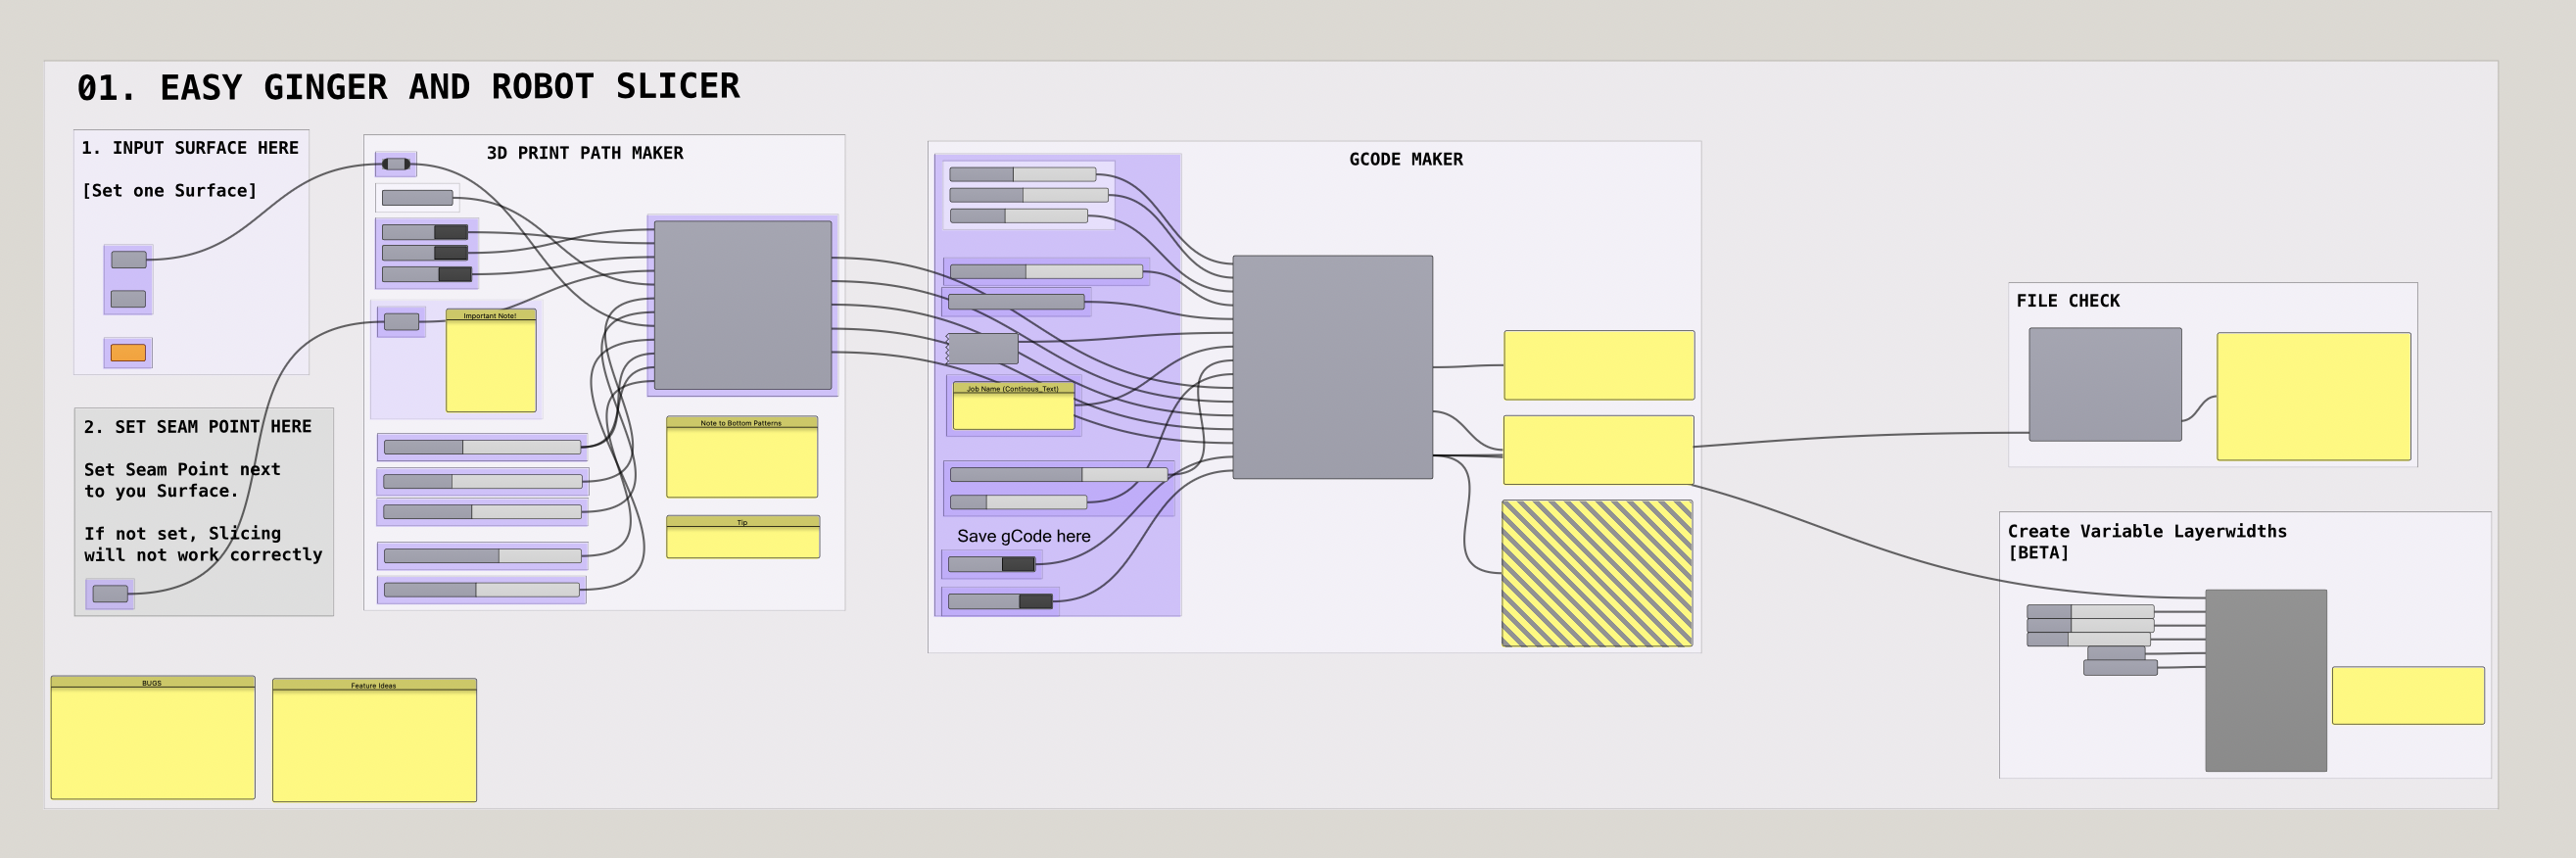
- Easy Slicer – slices a surface and creates the toolpath automatically: seam point, layer height, extrusion width, skirt and brim.
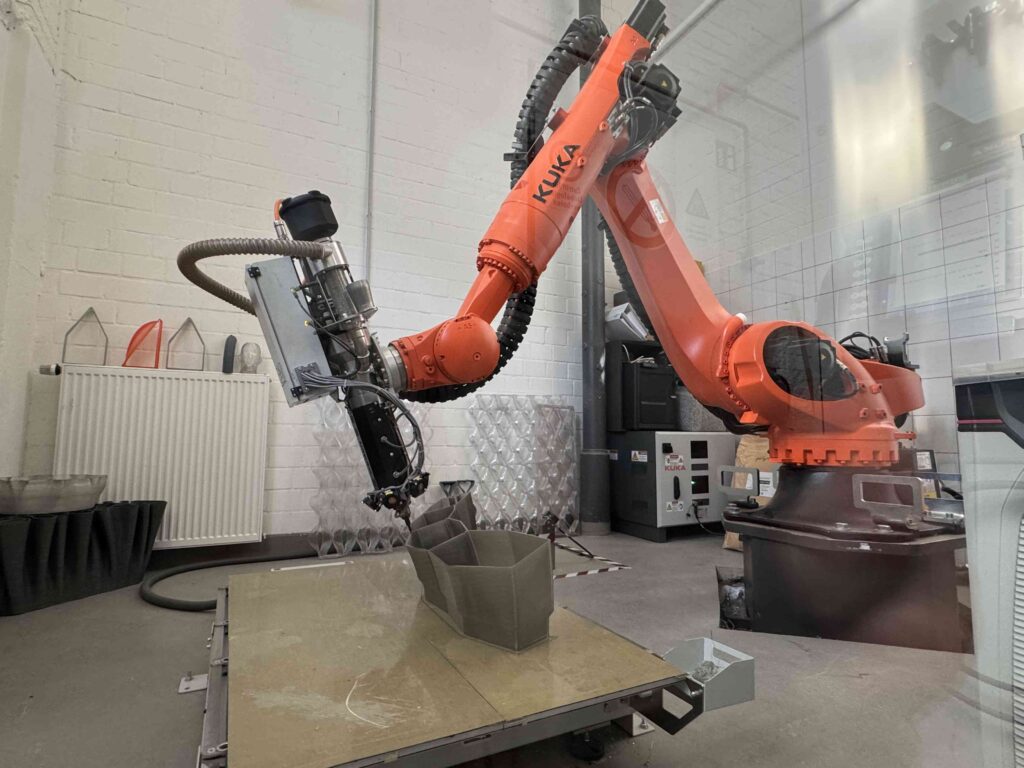
- Multiaxial Robot Slicer – turns the toolpath into multiaxial robot paths, including inclined printing planes and a preview of the robot movement.
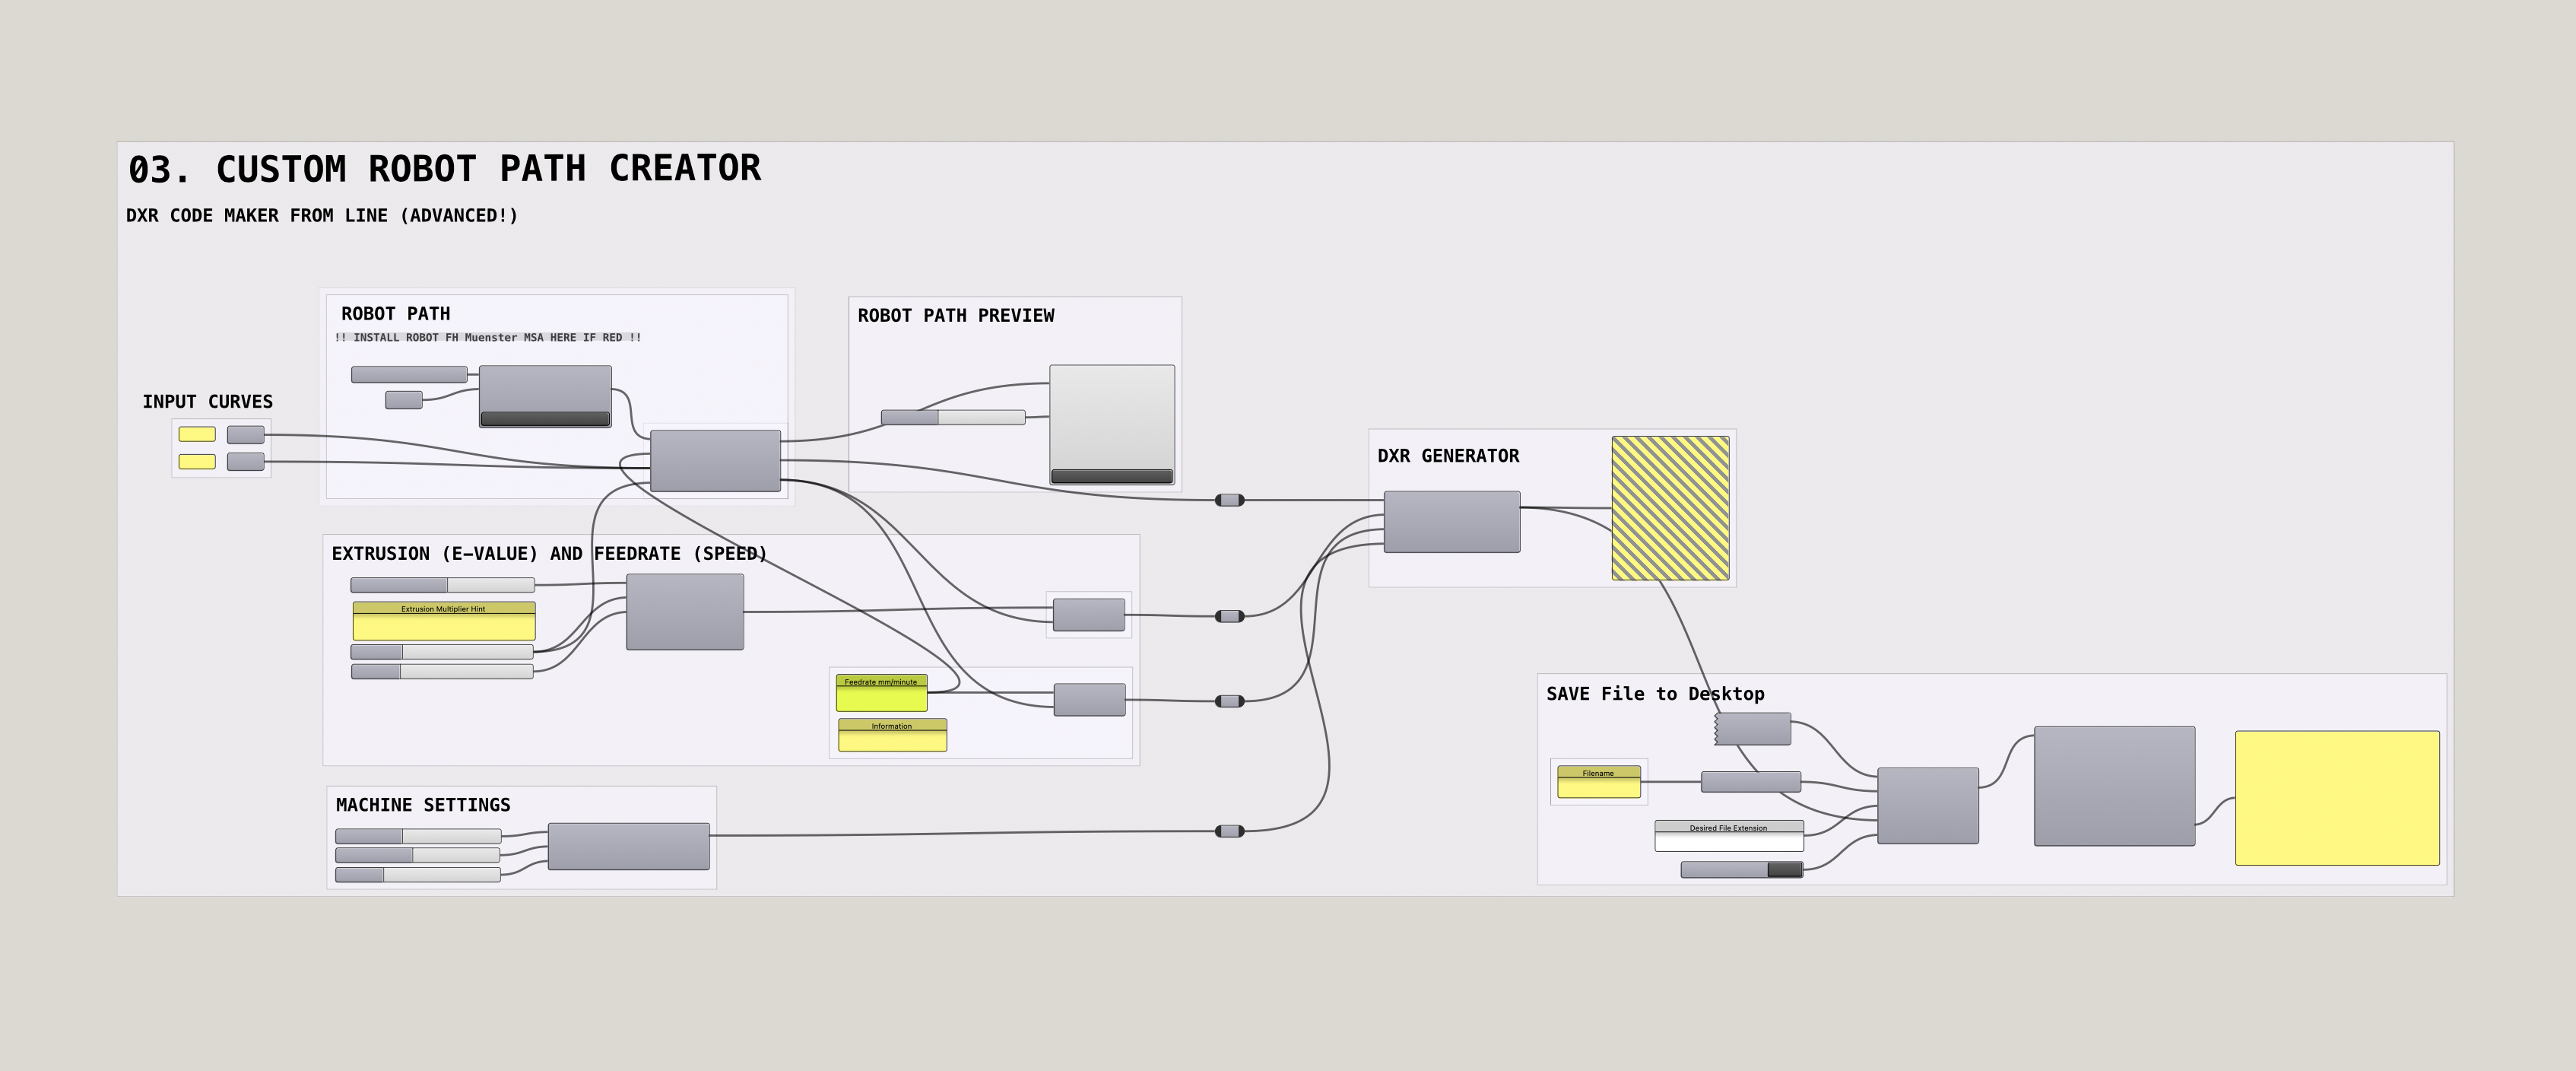
- Custom Robot Path Creator – converts your own curves and points directly into DXR robot code, with control over extrusion and feedrate.
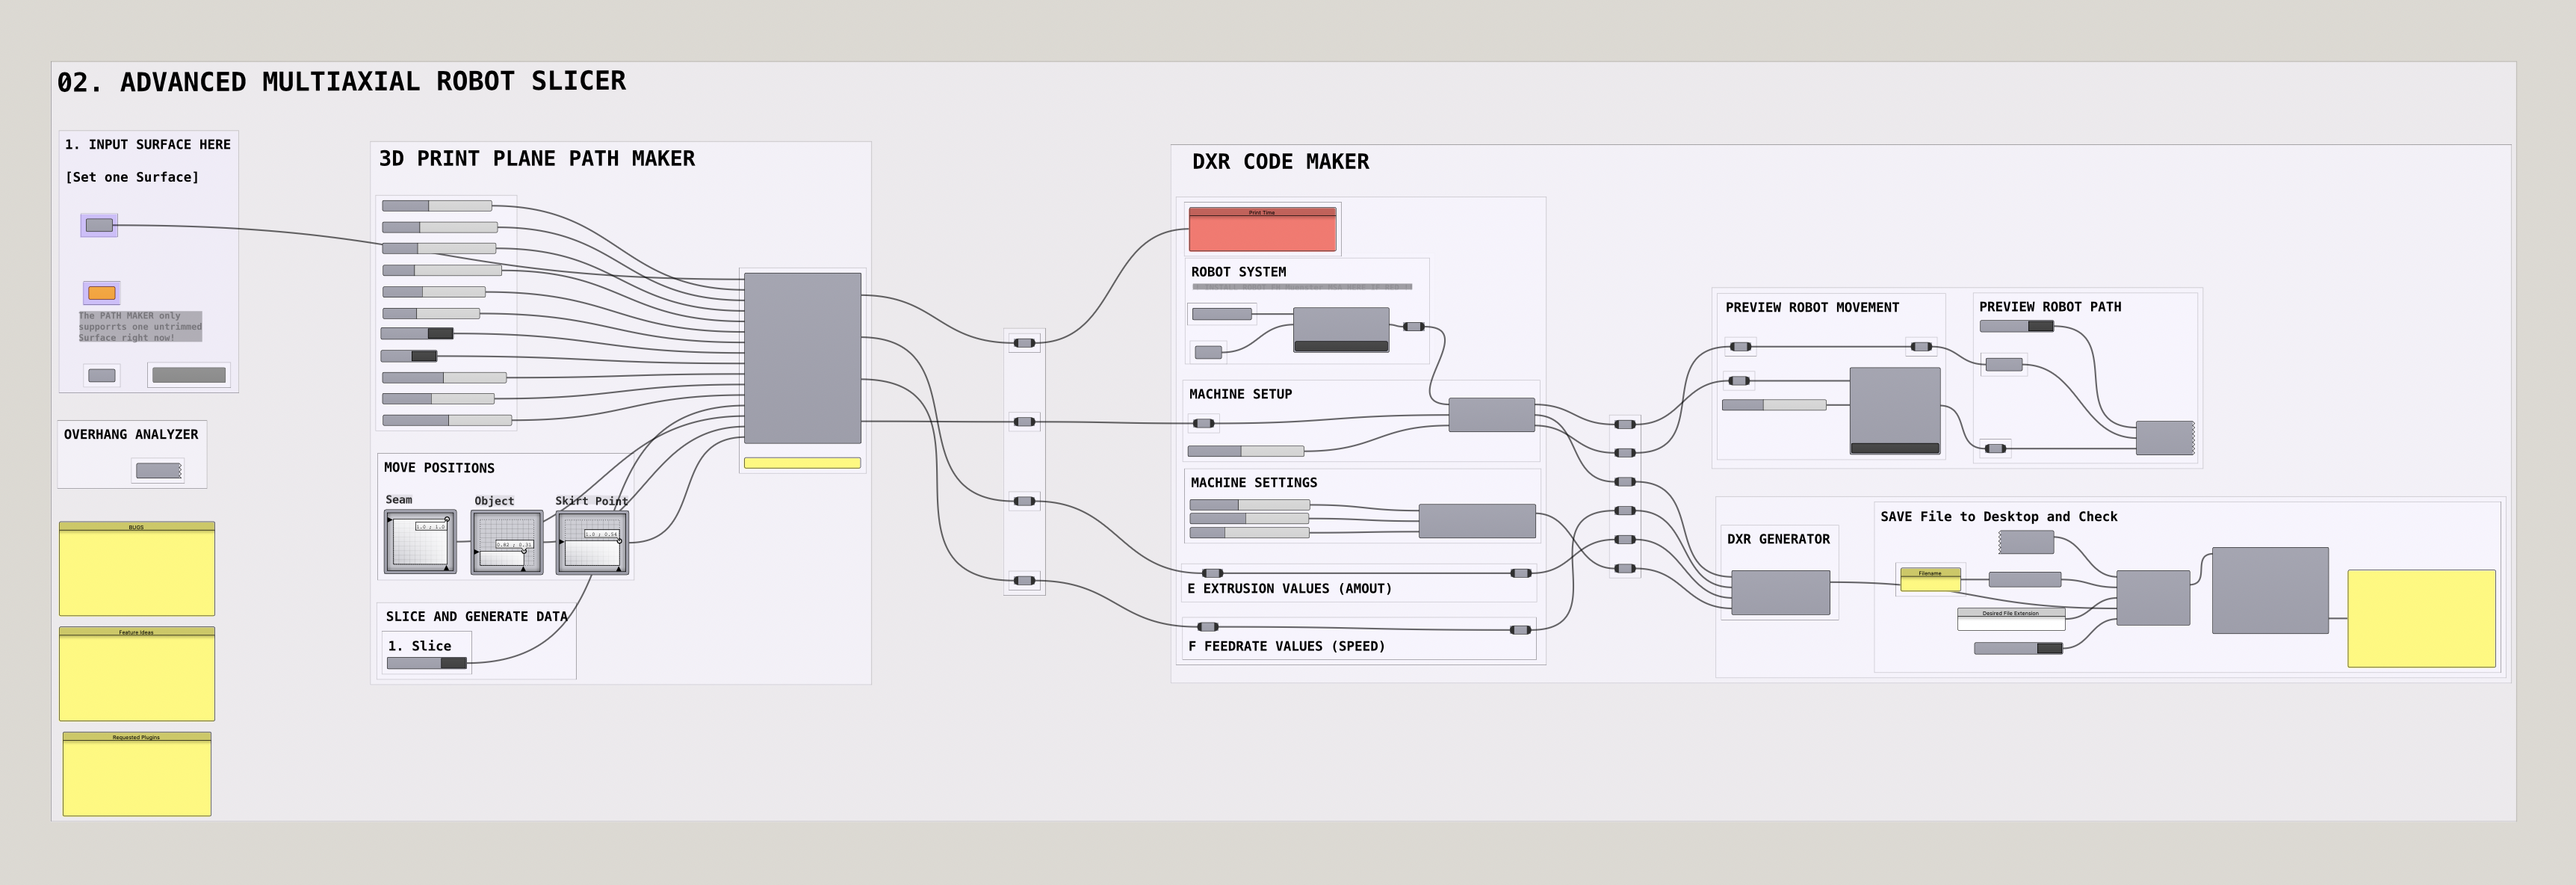
The video shows the multiaxial workflow in practice: the robot path is simulated in Grasshopper and then printed by the KUKA robot with an inclined extruder.
Built for the Workshop
- Preflight check – the DXR File Health Check validates every file before printing and returns GO or NO GO.
- Variable line widths – extrusion can be scaled along X, Y or Z, with a colour preview of the widths.
- Automatic header – runtime, layer count and extrusion totals are written into the robot code.
- One-click setup – an installer for Windows and macOS sets up all plugins and the KUKA KR120 robot library.
- Machine guides – operating and troubleshooting guides in German and English for the Weber DXR25, Ginger One, Universal Robots UR5 and the Zünd G3 cutter (3D milling via HPGL).
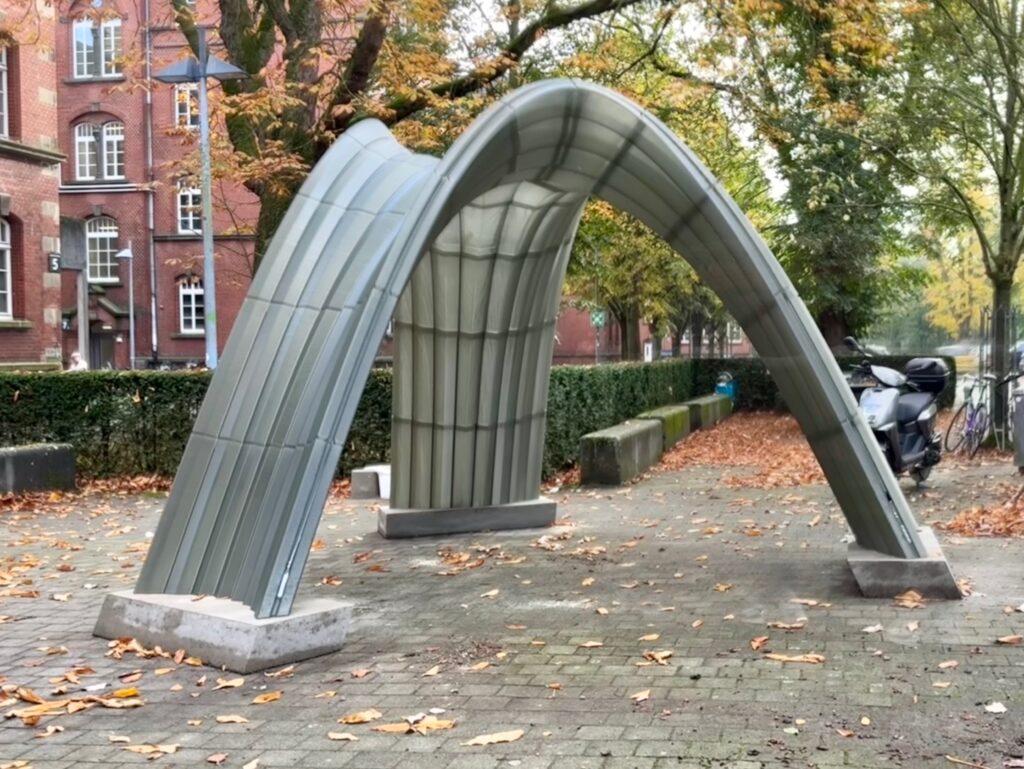
In Use: A Student Pavilion at FH Münster
Students Christian & Desislava Brunnert-Paneva designed a pavilion at FH Münster and printed it in the robotics.lab. The design is entirely theirs – the scripts behind LARGER.slicer converted the points of their Grasshopper model into robot code, and the lab supervised the robot. Read more about the student project.
Download
LARGER.slicer is available on GitHub and as the LARGERslicer plugin in the Rhino Package Manager. It runs on Rhino 8 (recommended) and Rhino 7, on Windows and macOS. Licence: CC BY-NC 4.0 – free for non-commercial use.
Contributors: Fabio Koczula and Claudio Schröder. Originally inspired by Ginger.Additive, fully reimplemented with support for more machines.
Your Machine, Your Process
Do you run a robot, a large-format printer or a CNC machine and want to generate machine code straight from your CAD data? We adapt the workflow to your machine, material and process – from a custom postprocessor to fully automated toolpaths.